Extend human reach
A tethered vehicle could take on repetitive survey and collection tasks while an operator remains responsible for targets and movement.
Kelp Recovery · Conservation robotics
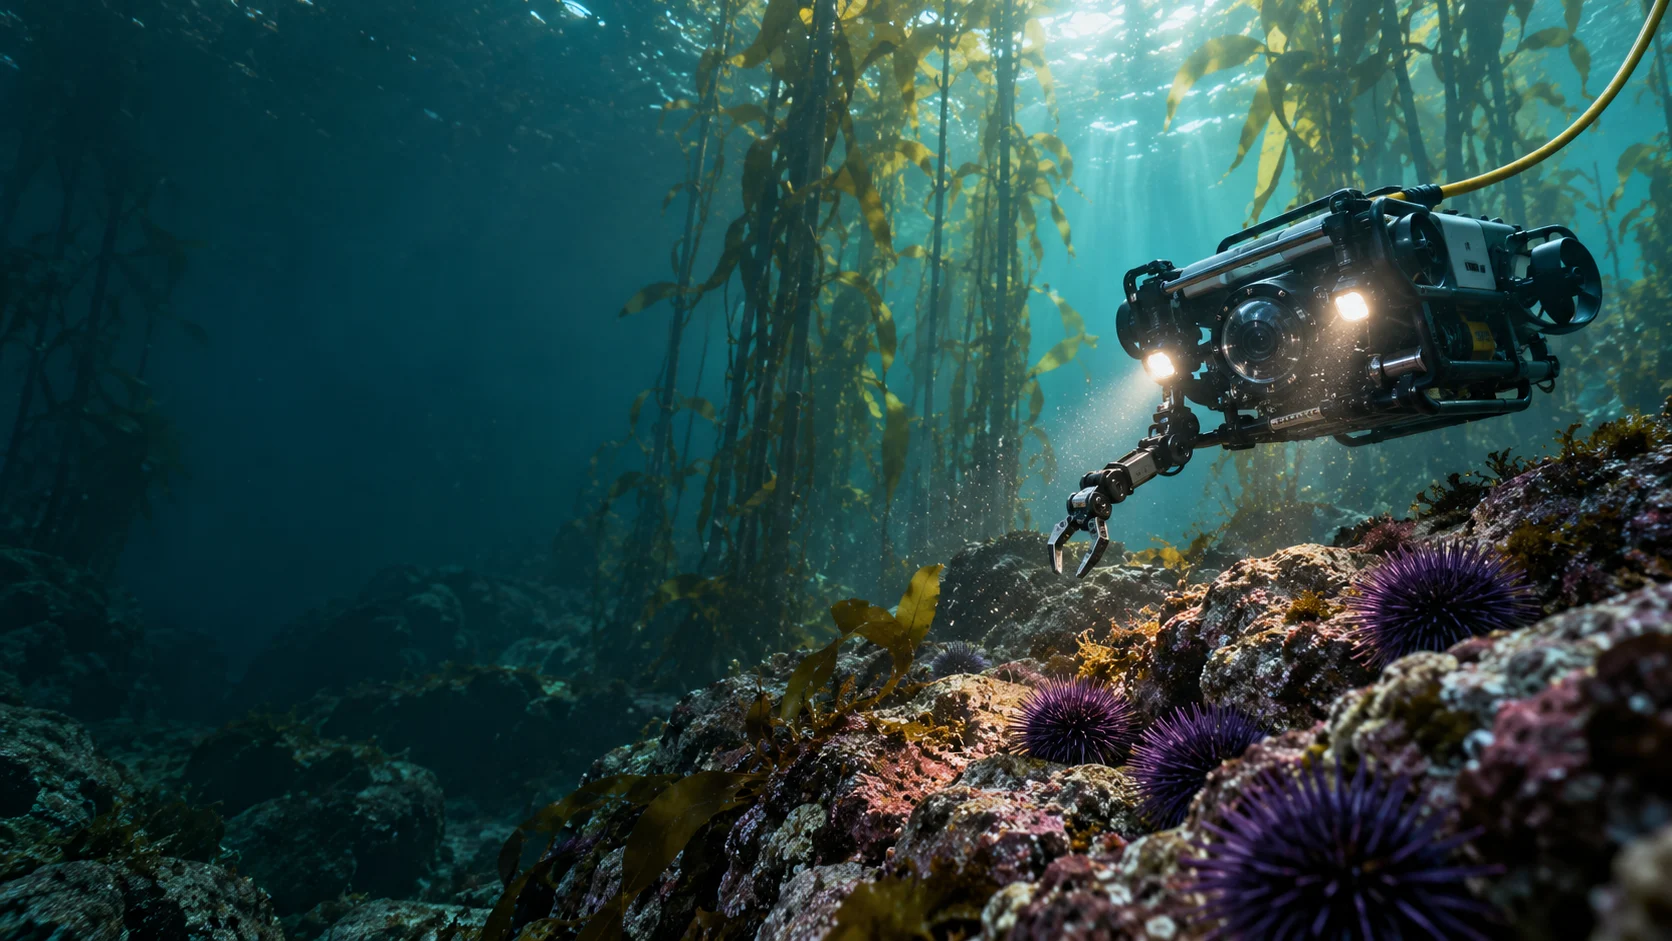
We are developing an operator-supervised ROV system to help restoration teams locate, approach, collect, and document purple sea urchins in bounded restoration areas.
Concept visualization · operator-supervised system
A working software foundation,
ready for physical integration.
Targeted action. Measured recovery.
When dense purple urchin populations maintain a barren, new kelp can be grazed before a forest re-establishes. Our objective is a selective, traceable intervention that helps qualified restoration teams act precisely in bounded areas.
The ROV is one instrument in a larger system. Each collection can be linked to location, habitat observations, treatment and control areas, and the evidence that matters most: whether a diverse kelp forest persists.
Extend expertise, not replace it
Divers bring ecological awareness and adaptability. Conventional ROVs extend visibility and reach. Our concept combines an operator’s judgment with assisted movement, selective manipulation, and automatic evidence capture.
A tethered vehicle could take on repetitive survey and collection tasks while an operator remains responsible for targets and movement.
Candidate sightings, approach decisions, collection events, and locations can become part of one traceable restoration record.
Repeatable observations could help restoration teams revisit bounded areas and compare treatment with ecological recovery over time.
The design favors supervised, target-by-target work rather than indiscriminate removal or unsupervised collection.
The validation question: Can operator-supervised robotics extend the precision of diver-led restoration into longer, repeatable, data-rich missions?
03 · Perception pipeline
We built a local pipeline that turns video into timestamped frames, passes them through an object-detection interface, and converts candidate locations into observations for tracking and navigation.
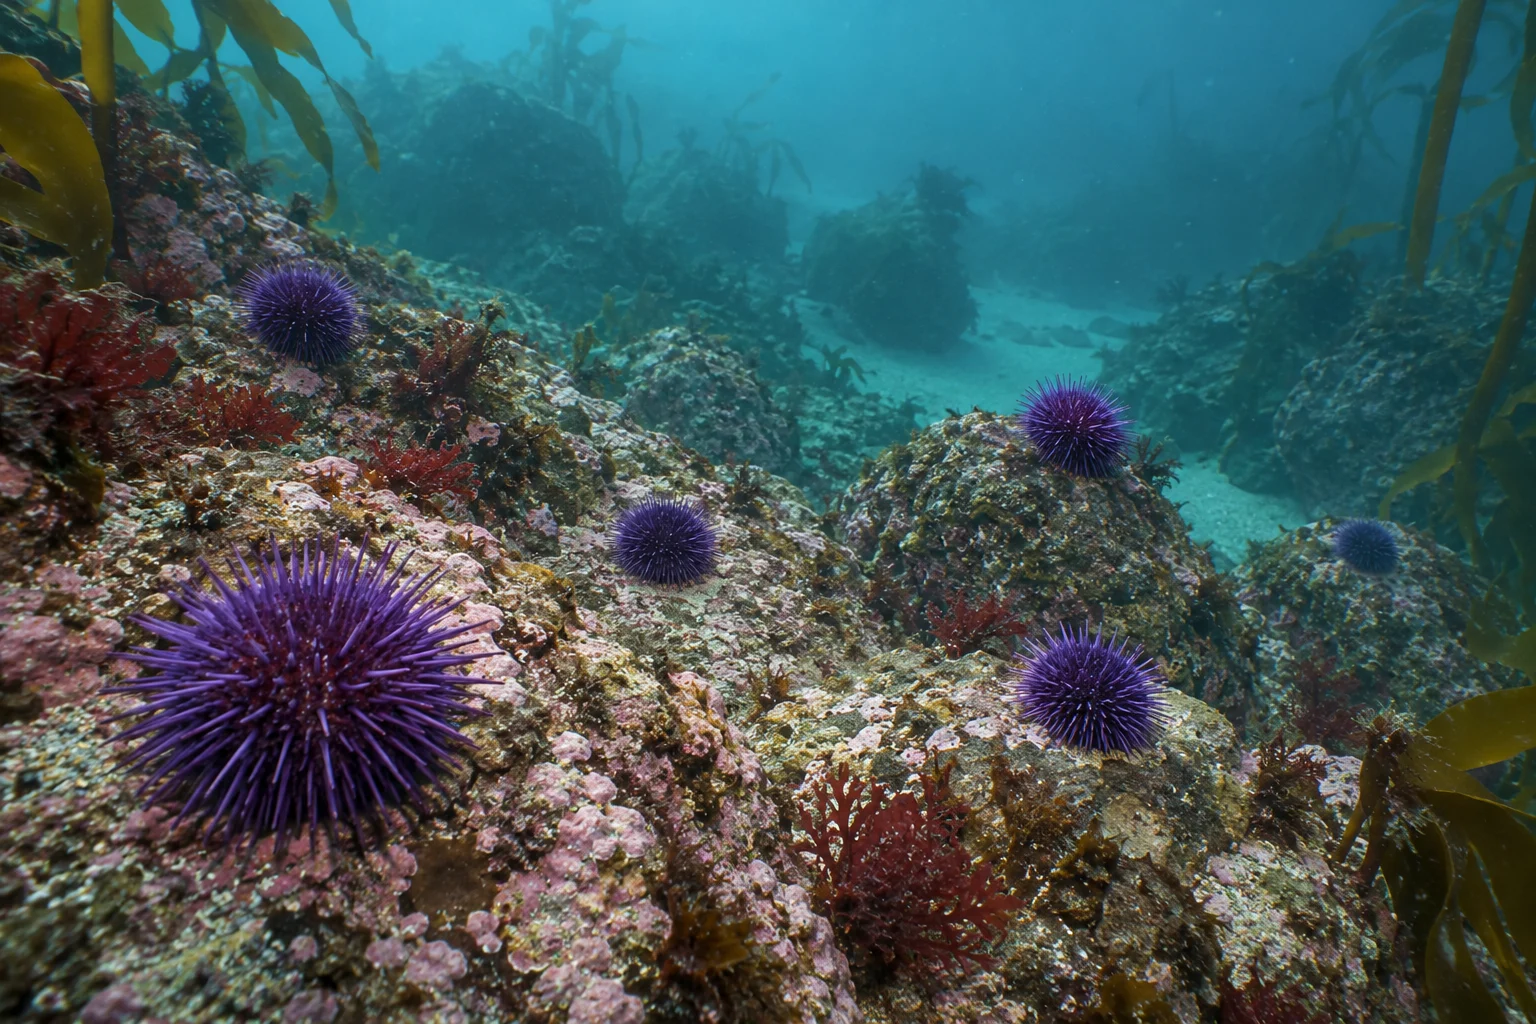 target 01candidate
target 02candidate
target 03candidate
target 04candidate
target 05candidate
target 06candidate
Prototype evidence
Video ingestion
A generated ten-second approach video proved the full media path: encoding, decoding, timestamped sampling, and frame-by-frame inference.
Decision engine
The vehicle-neutral policy aligns, advances in short pulses, verifies progress, and exits cleanly when it loses the target or fails to get closer.
Control authority
Assisted motion starts only after an explicit enable and a renewable control lease. Manual override returns authority before the next movement command.
Safety supervisor
Directional proximity sectors represent the contract for rocks, bottom clearance, unknown objects, and kelp or other entanglement hazards.
05 · Vehicle control
Our adapter communicates over MAVLink with ArduSub—the control software used by BlueROV-class vehicles. In Software-in-the-Loop, it verified heartbeat, mode, arming, telemetry, bounded movement, neutralization, and disarm.
01 connect SUBMARINE HEARTBEAT
02 authority OPERATOR ENABLED
03 approach 4 BOUNDED PULSES
04 capture CONFIRMATION REQUIRED
05 cleanup NEUTRAL · DISARMED
Local-first, modular by design
Compute-intensive development runs on the project’s Ubuntu workstation. The same interfaces can later connect recorded dives, live camera streams, physical range sensors, and a real ROV without rewriting the mission logic.
Python · PyTorch · OpenCV · object detection
frames → targetsTyped state machine · bounded approach policy
targets → intentAuthority lease · proximity sectors · abort states
intent → permitted intentArduSub · MAVLink · pymavlink · SITL
intent → telemetryUbuntu · Docker · project-isolated Kubernetes
local reproducibilityDesigned around human judgment
The pilot operates through the standard control interface and owns every maneuver.
The custom policy suggests and executes short, gated movements toward an approved target.
Any stale signal, hazard, expired lease, or operator input stops the custom controller.
Seeking an evaluation platform
WellThought Foundation is seeking a time-limited equipment loan, discounted development system, or technical partnership involving a BlueROV2-class vehicle or manufacturer-recommended equivalent.
Ideal evaluation package
A complete tethered platform suitable for bench and controlled-tank testing.
Live video plus the ArduSub/MAVLink interfaces already exercised by our software.
Configuration, safe integration practice, and advice on compatible sensors or manipulators.
A manipulator, proximity sensing, or ranging system would strengthen later test phases but is not required to begin.
What a hardware partner receives
Open the next conversation
We are opening conversations with ROV manufacturers, test facilities, restoration practitioners, marine scientists, technical contributors, and mission-aligned funders. The immediate objective is a responsible bench-to-tank program that can inform the first supervised field demonstration.